CyberSecurity Summary · Today · 27 min
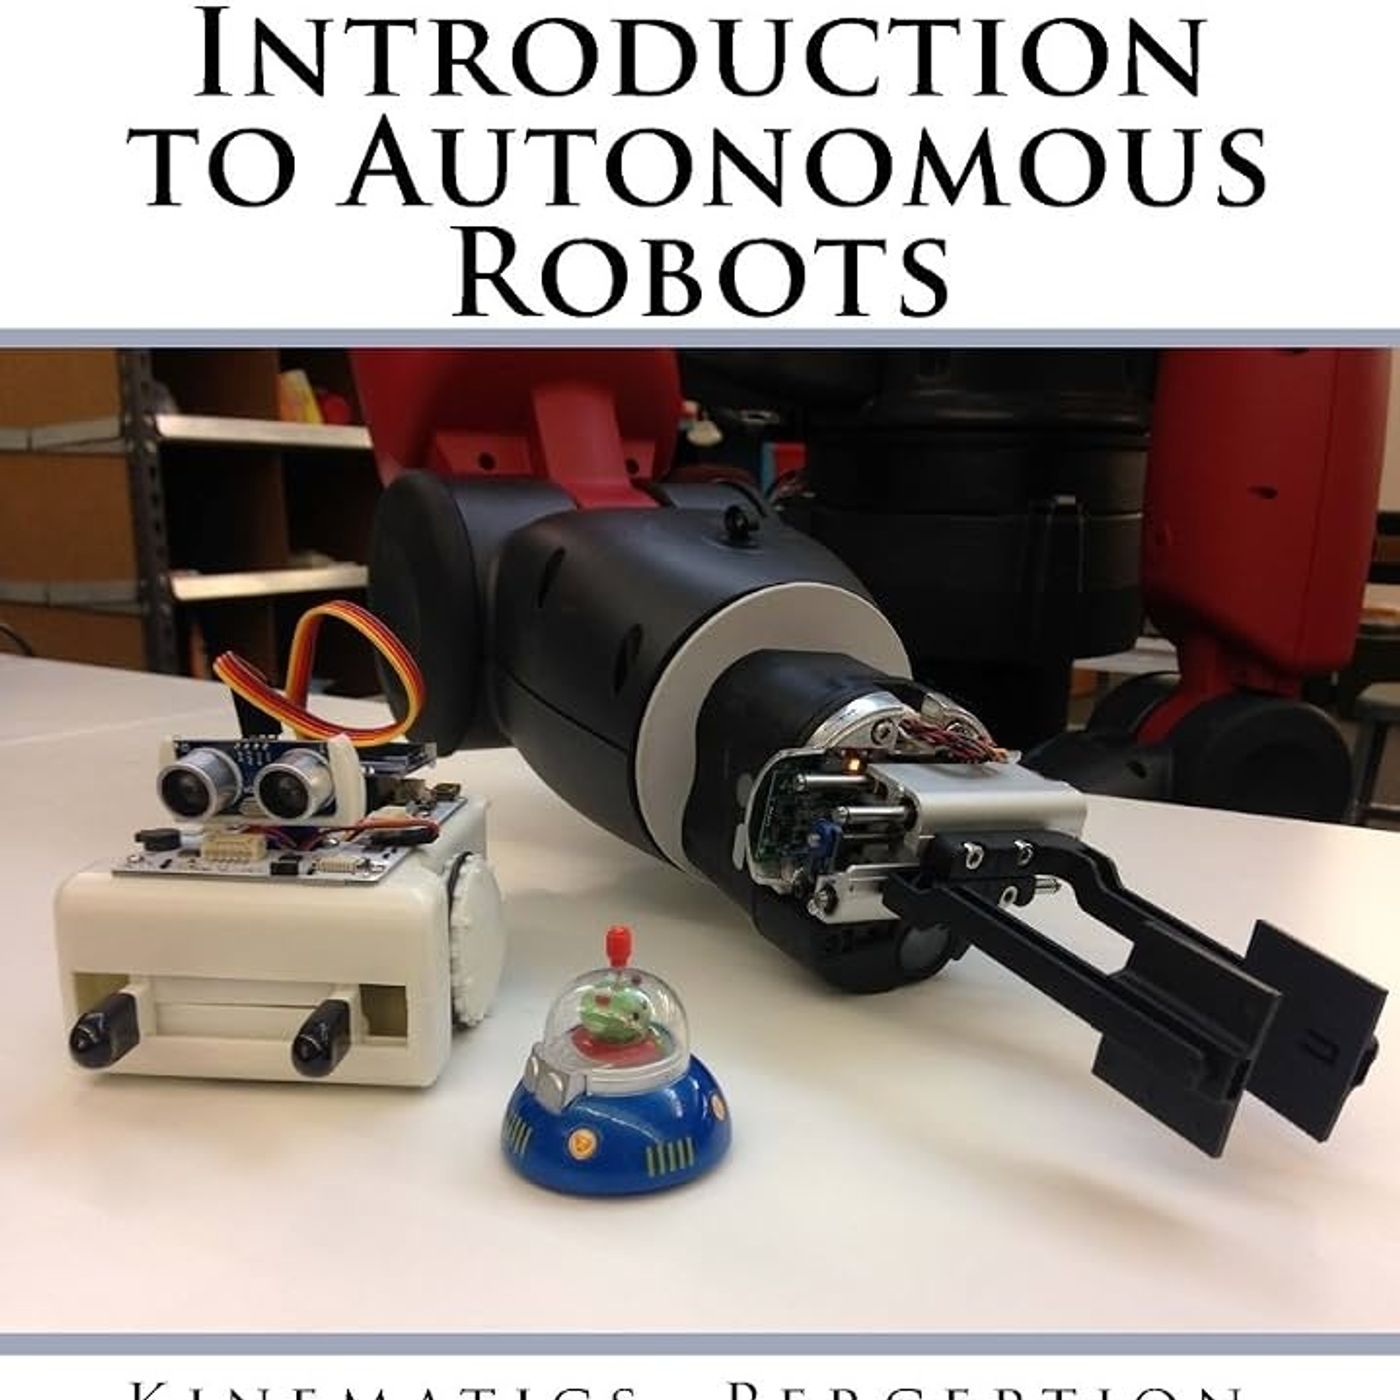
Introduction to Autonomous Robots
0:00-27:09
transcript
show notes
A comprehensive foundational textbook designed to teach the computational and algorithmic principles of robotics to undergraduate students. The text bridges the gap between mechanical engineering and computer science by exploring how robots sense, actuate, and navigate through uncertain real-world environments. Key topics include forward and inverse kinematics, path planning, and the mathematical frameworks of linear algebra and probability theory necessary for robot localization. The author emphasizes autonomous decision-making, contrasting complex electronic control with simple mechanical intelligence found in nature. Additionally, the book provides practical guidance on simultaneous localization and mapping (SLAM) and the challenges of dexterous manipulation. Released under a Creative Commons license, this resource encourages academic sharing while maintaining a structured curriculum for future roboticists.
You can listen and download our episodes for free on more than 10 different platforms:
https://linktr.ee/cyber_security_summary
Get the Book now from Amazon:
https://www.amazon.com/dp/1493773070?lv=shuf&channelId=500&plpRedirect=mhFallback&linkCode=ll2&tag=cvthunderx-20&linkId=aa54908128df3e3b59f2d5d53c9c5cba&language=en_US&gaOptInStatus=true&ref_=as_li_ss_tl
Discover our free courses in tech and cybersecurity, Start learning today:
https://linktr.ee/cybercode_academy
You can listen and download our episodes for free on more than 10 different platforms:
https://linktr.ee/cyber_security_summary
Get the Book now from Amazon:
https://www.amazon.com/dp/1493773070?lv=shuf&channelId=500&plpRedirect=mhFallback&linkCode=ll2&tag=cvthunderx-20&linkId=aa54908128df3e3b59f2d5d53c9c5cba&language=en_US&gaOptInStatus=true&ref_=as_li_ss_tl
Discover our free courses in tech and cybersecurity, Start learning today:
https://linktr.ee/cybercode_academy
links3
- https://linktr.ee/cyber_security_summarylinktr.ee
- https://www.amazon.com/dp/1493773070?lv=shuf&channelId=500&plpRedirect=mhFallback&linkCode=ll2&tag=cvthunderx-20&linkId=aa54908128df3e3b59f2d5d53c9c5cba&language=en_US&gaOptInStatus=true&ref_=as_li_ss_tlamazon.com
- https://linktr.ee/cybercode_academylinktr.ee