Skip to content
Artwork for CDFAM Computational Design Symposium
CDFAM Computational Design Symposium · September 14 · 34 min

Authoring Autonomy

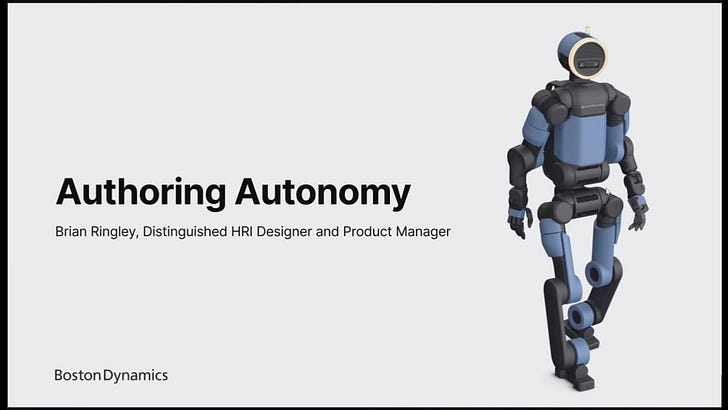
CDFAM Computational Design Symposium — Washington DC 2026 Brian Ringley · Boston Dynamics Atlas is a general-purpose humanoid aimed squarely at industrial work, and Brian Ringley makes the case that its value is economic rather than technological. Most of the automation gaps on a factory floor could be closed with conventional equipment; what makes that impractical is designing a bespoke solution for each one. A single investment in generalised hardware turns all of those separate problems into one software problem, which is a far cheaper thing to solve. The talk walks through the industrial design decisions that follow from putting a machine into shared human space. Why the robot has a head and a face that turns: perception needs to sit at eye level, and a gaze tells a person nearby that they have been seen and hints at what the robot will do next. Why it reads as equipment rather than as a person. And why only two actuator types appear across the whole machine, giving a blocky, repetitive design language in exchange for cost, reliability and field-replaceable parts, with continuously rotating joints that let it work in ways a human body cannot. The second half is about teaching it to do useful work. Ringley lays out the current stack — reinforcement learning for whole-body control, behaviour cloning from VR teleoperation for manipulation, and a vision-language model above both for reasoning and tool calls — and is candid that the hard constraint is data. There is no internet-scale corpus of action data, so it has to be produced: pilots suited up in VR on real plant floors, training in simulation to remove latency, and supervised correction where a human takes control mid-policy to annotate what went wrong. Running underneath is an argument about authorship, that the line between who writes software and who uses it has largely dissolved, and that the world itself is becoming the arena in which this software is trained. Links Talk page with full transcript Watch the talk on YouTube Cite this talk Search the full text of every recorded CDFAM presentation This is a public episode. If you would like to discuss this with other subscribers or get access to bonus episodes, visit www.designforam.com
0:00-34:07

transcript

No transcript — this publisher did not publish one.

show notes

CDFAM Computational Design Symposium — Washington DC 2026

Brian Ringley · Boston Dynamics

Atlas is a general-purpose humanoid aimed squarely at industrial work, and Brian Ringley makes the case that its value is economic rather than technological. Most of the automation gaps on a factory floor could be closed with conventional equipment; what makes that impractical is designing a bespoke solution for each one. A single investment in generalised hardware turns all of those separate problems into one software problem, which is a far cheaper thing to solve.

The talk walks through the industrial design decisions that follow from putting a machine into shared human space. Why the robot has a head and a face that turns: perception needs to sit at eye level, and a gaze tells a person nearby that they have been seen and hints at what the robot will do next. Why it reads as equipment rather than as a person. And why only two actuator types appear across the whole machine, giving a blocky, repetitive design language in exchange for cost, reliability and field-replaceable parts, with continuously rotating joints that let it work in ways a human body cannot.

The second half is about teaching it to do useful work. Ringley lays out the current stack — reinforcement learning for whole-body control, behaviour cloning from VR teleoperation for manipulation, and a vision-language model above both for reasoning and tool calls — and is candid that the hard constraint is data. There is no internet-scale corpus of action data, so it has to be produced: pilots suited up in VR on real plant floors, training in simulation to remove latency, and supervised correction where a human takes control mid-policy to annotate what went wrong. Running underneath is an argument about authorship, that the line between who writes software and who uses it has largely dissolved, and that the world itself is becoming the arena in which this software is trained.

Links

Talk page with full transcript

Watch the talk on YouTube

Cite this talk

Search the full text of every recorded CDFAM presentation


This is a public episode. If you would like to discuss this with other subscribers or get access to bonus episodes, visit www.designforam.com
links6